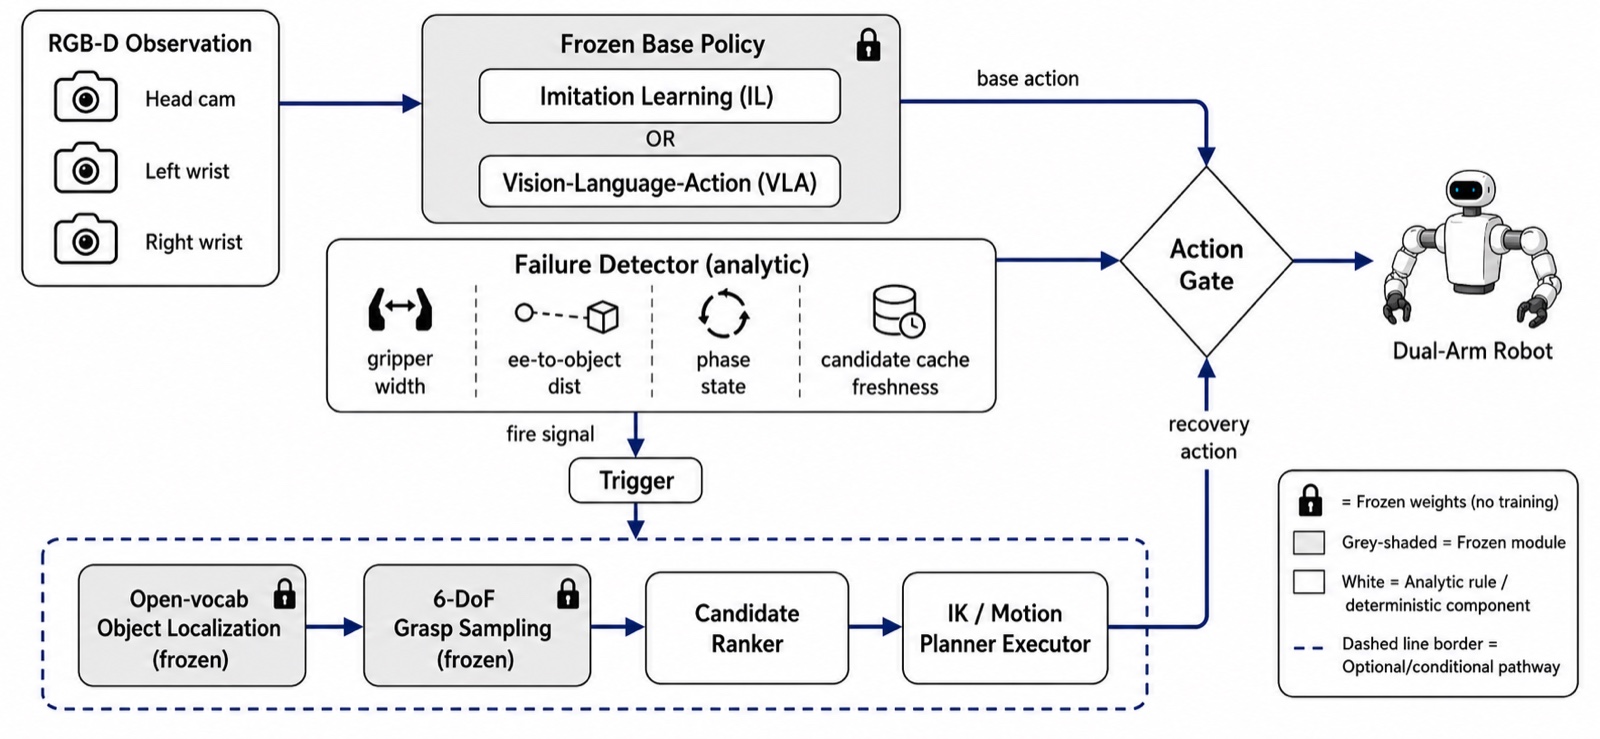
Robots that learn by watching us, and by trying for themselves.
M.S. Robotics student at Georgia Tech. Actively seeking Summer 2027 research internships.
I am an M.S. student in Robotics at Georgia Tech. Before that, I completed a dual-degree program in 2026, earning a B.S. in Computer Engineering from the University of Illinois Urbana-Champaign and a B.E. in Electrical and Computer Engineering from Zhejiang University.
As an undergraduate I worked with Prof. Liangjing Yang, Prof. Katie Driggs-Campbell, and Prof. Gaoang Wang. My research focuses on robot learning, dexterous manipulation, and perception.
Research question
How should a robot represent a dexterous skill it learns from a few human demonstrations, so the skill stays predictable and can adapt when a new setting brings uncertainty?
@InProceedings{Deng_2025_CVPR,
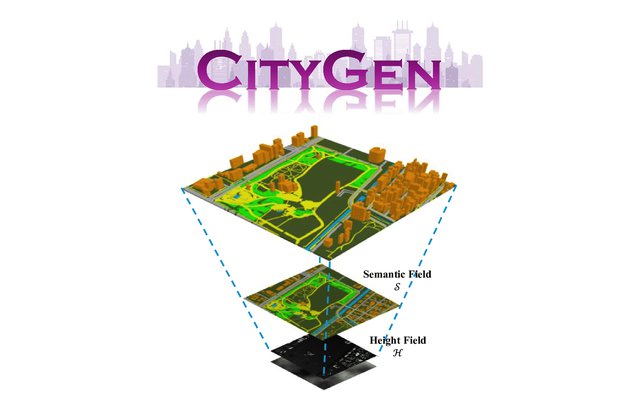
title = {CityGen: Infinite and Controllable City Layout Generation},
author = {Deng, Jie and Chai, Wenhao and Guo, Jianshu and Huang, Qixuan and Hu, Wenhao and Hwang, Jenq-Neng and Wang, Gaoang},
booktitle = {Proceedings of the Computer Vision and Pattern Recognition Conference (CVPR) Workshops},
year = {2025}
}
@article{deng2024citycraft,
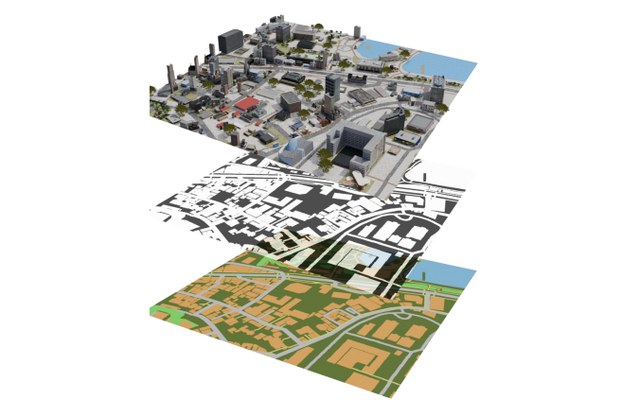
title = {CityCraft: A Real Crafter for 3D City Generation},
author = {Deng, Jie and Chai, Wenhao and Huang, Junsheng and Zhao, Zhonghan and Huang, Qixuan and Gao, Mingyan and Guo, Jianshu and Hao, Shengyu and Hu, Wenhao and Hwang, Jenq-Neng and Li, Xi and Wang, Gaoang},
journal = {arXiv preprint arXiv:2406.04983},
year = {2024}
}
Course project HyperGemini: Autonomous Parallel Parking · Jan – May 2025 · ROS, GEM e2, 4/5 physical trials
Format adapted from Wenhao Chai's Experiments.